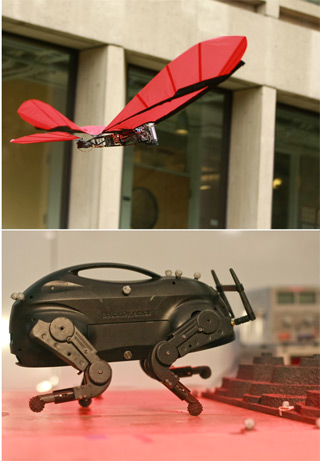
Course6.83223 lectures28 h 28 min
Underactuated Robotics
Prof. Russell Tedrake · Massachusetts Institute of Technology
About
Robots today move far too conservatively, using control systems that attempt to maintain full control authority at all times. Humans and animals move much more aggressively by routinely executing motions which involve a loss of instantaneous control authority. Controlling nonlinear systems without complete control authority requires methods that can reason about and exploit the natural dynamics of our machines.
This course discusses nonlinear dynamics and control of underactuated mechanical systems, with an emphasis on machine learning methods. Topics include nonlinear dynamics of passive robots (walkers, swimmers, flyers), motion planning, partial feedback linearization, energy-shaping control, analytical optimal control, reinforcement learning/approximate optimal control, and the influence of mechanical design on control. Discussions include examples from biology and applications to legged locomotion, compliant manipulation, underwater robots, and flying machines.
Acknowledgments
Professor Tedrake would like to thank John Roberts for his help with the course and videotaping the lectures.
Lectures
Video Lectures
- Lecture 1: Introduction
- Lecture 2: The Simple Pendulum
- Lecture 3: Optimal Control of the Double Integrator
- Lecture 4: Optimal Control of the Double Integrator (cont.)
- Lecture 5: Numerical Optimal Control (Dynamic Programming)
- Lecture 6: Acrobot and Cart-pole
- Lecture 7: Swing-up Control of Acrobot and Cart-pole Systems
- Lecture 8: Dynamic Programming (DP) and Policy Search
- Lecture 9: Trajectory Optimization
- Lecture 10: Trajectory Stabilization and Iterative Linear Quadratic Regulator
- Lecture 11: Walking
- Lecture 12: Walking (cont.)
- Lecture 13: Running
- Lecture 14: Feasible Motion Planning
- Lecture 15: Global Policies from Local Policies
- Lecture 16: Introducing Stochastic Optimal Control
- Lecture 17: Stochastic Gradient Descent
- Lecture 18: Stochastic Gradient Descent 2
- Lecture 19: Temporal Difference Learning
- Lecture 20: Temporal Difference Learning with Function Approximation
- Lecture 21: Policy Improvement
- Lecture 22: Actor-critic Methods
- Lecture 23: Case Studies in Computational Underactuated Control
Syllabus and materials
At MIT OpenCourseWare, as the course publishes them.
Credits and licence
- Institution
- Massachusetts Institute of Technology
- Department
- Electrical Engineering and Computer Science
- Teacher
- Prof. Russell Tedrake
- Term
- Spring 2009
- Level
- Graduate
- Language
- English
- Subjects
- Computer science, Engineering
- Source
- MIT OpenCourseWare
- Licence
- CC BY-NC-SA 4.0, as MIT OpenCourseWare states it. Non-commercial use only. MIT OpenCourseWare's terms
- Attribution
- Prof. Russell Tedrake. Underactuated Robotics. Spring 2009. Massachusetts Institute of Technology: MIT OpenCourseWare, https://ocw.mit.edu/. License: Creative Commons BY-NC-SA.
- Who can watch
- MIT OpenCourseWare gives no rating. Invisible Network shows it to Tweens profiles and older, judged from what the source says about it. How courses are placed
More like this
 Course
Matrix Methods in Data Analysis, Signal Processing, and Machine Learning
34 lectures · Video
 Course
Computational Science and Engineering I
50 lectures · Video
 Course
Engineering Dynamics
223 lectures · Video
 Course
Becoming the Next Bill Nye: Writing and Hosting the Educational Show
132 lectures · Video
 Course
Introduction to Nuclear Engineering and Ionizing Radiation
34 lectures · Video
 Course
Thermodynamics of Materials
38 lectures · Video
 Course
Introduction to Solid-State Chemistry
38 lectures · Video
 Course
Introduction to Solid State Chemistry
62 lectures · Video
 Course
Symmetry, Structure, and Tensor Properties of Materials
43 lectures · Video
 Course
Computation Structures
35 lectures · Video
 Course
Introduction to Algorithms
47 lectures · Video
 Course
Introduction to Electrical Engineering and Computer Science I
54 lectures · Video