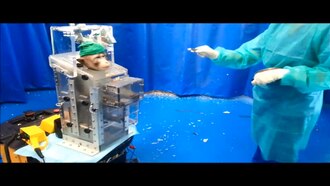
Independent-Mobility-Achieved-through-a-Wireless-Brain-Machine-Interface-pone.0165773.s006
Libedinsky C, So R, Xu Z, Kyar T, Ho D, Lim C, Chan L, Chua Y, Yao L, Cheong J, Lee J, Vishal K, Guo Y, Chen Z, Lim L, Li P, Liu L, Zou X, Ang K, Gao Y, Ng W,…
Science
Make a clip
CC BY 4.0 · Libedinsky C, So R, Xu Z, Kyar T, Ho D, Lim C, Chan L, Chua Y, Yao L, Cheong J, Lee J, Vishal K, Guo Y, Chen Z, Lim L, Li P, Liu L, Zou X, Ang K, Gao Y, Ng W, Han B, Chng K, Guan C, Je M, Yen S
Up to 60 seconds, at most the picture size of the copy it is cut from. The clip carries the title, the credit, the licence and a link back here. It is made in this browser, and nothing is sent to this site.
Or send the moment itself: https://invisiblenetwork.ai/watch/archive/commons/55640032?play=1&t=0
Parts
About
Recalibrated Decoder without joystick, free movement task. The platform was controlled by the Recalibrated Decoder in the absence of a joystick. The animal was performing the free movement task, where the goal was to reach the trainer location and the platform was continuously under the monkeys’ control.
Human-made No record of this work says a model made it. What this means.
More from Wikimedia Commons
 Short
Curiosity's Seven Minutes of Terror
 Cartoon
Animation of the anatomy and physiology of the human brain AS
 Short
Liquid crystals
 Short
Properties of Hydrogen - Chemistry for All - FuseSchool
 Cartoon
Galaxy Collision Animation- James Webb Space Telescope Science
 Short
Mars2020Rover-SampleCollectionStorage-20200206
 Short
YBCO video
 Short
Potassium plasma
 Short
Wilson chamber
 Short
09. Гасење вар како силно егзотермен процес
 Short
Red weaver ants transporting a dead gecko, in Laos (video)
 Short