Information-Driven-Self-Organization-of-Complex-Robotic-Behaviors-pone.0063400.s003
Martius G, Der R, Ay N
Science
Make a clip
CC BY 2.5 · Martius G, Der R, Ay N
Up to 60 seconds, at most the picture size of the copy it is cut from. The clip carries the title, the credit, the licence and a link back here. It is made in this browser, and nothing is sent to this site.
Or send the moment itself: https://invisiblenetwork.ai/watch/archive/commons/26430776?play=1&t=0
Parts
About
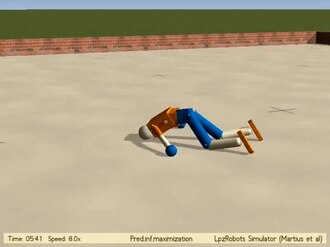
Humanoid robot on the ground. One high-dimensional TiPI maximizing controller is used here (17 DoF). The controller starts from a small unit initialization, causing the robot to lay calmly. After an initial phase where the parameters adjust to create some activity we observe smooth patterns of behavior that patterns come and go with time. Within short time intervals one sees several repetitions of one mode until it vanishes and a new one emerges. Parameters: (epsilon = 0.0002, eta = 0.1).
Human-made No record of this work says a model made it. What this means.
More from Wikimedia Commons
 Short
Curiosity's Seven Minutes of Terror
 Cartoon
Animation of the anatomy and physiology of the human brain AS
 Short
Liquid crystals
 Short
Properties of Hydrogen - Chemistry for All - FuseSchool
 Cartoon
Galaxy Collision Animation- James Webb Space Telescope Science
 Short
Mars2020Rover-SampleCollectionStorage-20200206
 Short
YBCO video
 Short
Potassium plasma
 Short
Wilson chamber
 Short
09. Гасење вар како силно егзотермен процес
 Short
Red weaver ants transporting a dead gecko, in Laos (video)
 Short