Opening the book…
A vector in a plane is represented by a directed line segment (an arrow). The endpoints of the segment are called the initial point and the terminal point of the vector. An arrow from the initial point to the terminal point indicates the direction of the vector. The length of the line segment represents its magnitude. We use the notation \(\|\vecs{v}\|\) to denote the magnitude of the vector \(\vecs{v}\). A vector with an initial point and terminal point that are the same is called the zero vector, denoted \(\vecs{0}\). The zero vector is the only vector without a fixed direction, and by convention can be considered to have any direction convenient to the problem at hand.
Vectors with the same magnitude and direction are called equivalent vectors. We treat equivalent vectors as equal, even if they have different initial points. Thus, if \(\vecs{v}\) and \(\vecs{w}\) are equivalent, we write
\[\vecs{v}=\vecs{w} \nonumber \]
Vectors are said to be equivalent vectors if they have the same magnitude and direction.
The arrows in Figure \(\PageIndex{9 (b)}\) are equivalent. Each arrow has the same length and direction. A closely related concept is the idea of parallel vectors. Two vectors are said to be parallel if they have identical or opposite directions. We explore this idea in more detail later in the chapter. A vector is defined by its magnitude and direction, regardless of where its initial point is located.
The use of boldface, lowercase letters to name vectors is a common representation in print, but there are alternative notations. When writing the name of a vector by hand, for example, it is easier to sketch an arrow over the variable than to show it is a vector: \(\vecs{v}\). When a vector has initial point \(P\) and terminal point \(Q\), the notation \(\vecd{PQ}\) is useful because it indicates the direction and location of the vector.
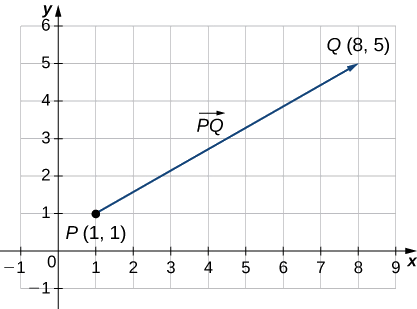
Sketch a vector in the plane from initial point \(P(1,1)\) to terminal point \(Q(8,5)\).
Because the vector goes from point \(P\) to point \(Q\), we name it \(\vecd{PQ}\).
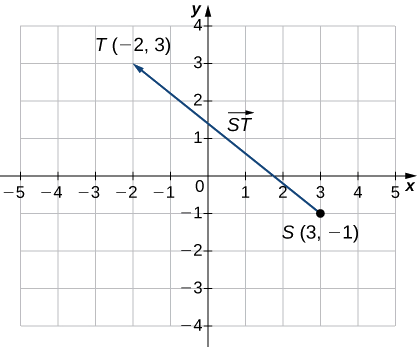
Sketch the vector \(\vecd{ST}\) where \(S\) is point \((3,−1)\) and \(T\) is point \((−2,3).\)
Solution
Vectors have many real-life applications, including situations involving force or velocity. For example, consider the forces acting on a boat crossing a river. The boat’s motor generates a force in one direction, and the current of the river generates a force in another direction. Both forces are vectors. We must take both the magnitude and direction of each force into account if we want to know where the boat will go.
A second example that involves vectors is a quarterback throwing a football. The quarterback does not throw the ball parallel to the ground; instead, he aims up into the air. The velocity of his throw can be represented by a vector. If we know how hard he throws the ball (magnitude—in this case, speed), and the angle (direction), we can tell how far the ball will travel down the field.
A real number is often called a scalar in mathematics and physics. Unlike vectors, scalars are generally considered to have a magnitude only, but no direction. Multiplying a vector by a scalar changes the vector’s magnitude. This is called scalar multiplication. Note that changing the magnitude of a vector does not indicate a change in its direction. For example, wind blowing from north to south might increase or decrease in speed while maintaining its direction from north to south.
The product \(k\vecs{v}\) of a vector \(\vecs{v}\) and a scalar \(k\) is a vector with a magnitude that is \(|k|\) times the magnitude of \(\vecs{v}\), and with a direction that is the same as the direction of \(\vecs{v}\) if \(k>0\), and opposite the direction of \(\vecs{v}\) if \(k<0\). This is called scalar multiplication. If \(k=0\) or \(\vecs{v}=\vecs{0}\), then \(k\vecs{v}=\vecs{0}.\)
As you might expect, if \(k=−1\), we denote the product \(k\vecs{v}\) as
\[k\vecs{v}=(−1)\vecs{v}=−\vecs{v} \nonumber \]
Note that \(−\vecs{v}\) has the same magnitude as \(\vecs{v}\), but has the opposite direction.
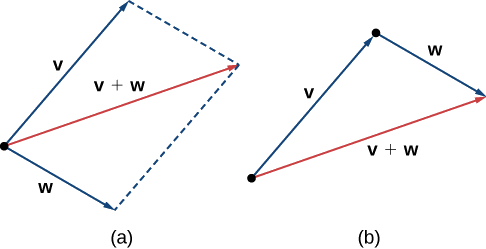
Another operation we can perform on vectors is to add them together in vector addition, but because each vector may have its own direction, the process is different from adding two numbers. The most common graphical method for adding two vectors is to place the initial point of the second vector at the terminal point of the first, as in Figure \(\PageIndex{11a}\).
The sum of two vectors \(\vecs{v}\) and \(\vecs{w}\) can be constructed graphically by placing the initial point of \(\vecs{w}\) at the terminal point of \(\vecs{v}\). Then, the vector sum, \(\vecs{v}+\vecs{w}\), is the vector with an initial point that coincides with the initial point of \(\vecs{v}\) and has a terminal point that coincides with the terminal point of \(\vecs{w}\). This operation is known as vector addition.
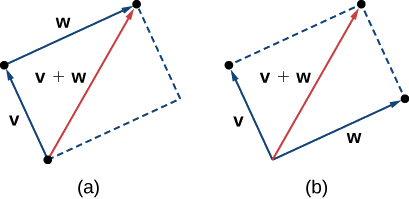
To see why this makes sense, suppose, for example, that both vectors represent displacement. If an object moves first from the initial point to the terminal point of vector \(\vecs{v}\), then from the initial point to the terminal point of vector \(\vecs{w}\), the overall displacement is the same as if the object had made just one movement from the initial point to the terminal point of the vector \(\vecs{v}+\vecs{w}\). For obvious reasons, this approach is called the triangle method. Notice that if we had switched the order, so that \(\vecs{w}\) was our first vector and \(\vecs{v}\) was our second vector, we would have ended up in the same place. Thus,
\[ \vecs{v}+ \vecs{w}= \vecs{w}+ \vecs{v} \nonumber \]
A second method for adding vectors is called the parallelogram method. With this method, we place the two vectors so they have the same initial point, and then we draw a parallelogram with the vectors as two adjacent sides, as in Figure \(\PageIndex{11b}\). The length of the diagonal of the parallelogram is the sum. Comparing Figure \(\PageIndex{11b}\) and Figure \(\PageIndex{11a}\), we can see that we get the same answer using either method. The vector \( \vecs{v}+ \vecs{w}\) is called the vector sum.
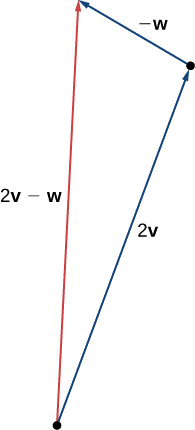
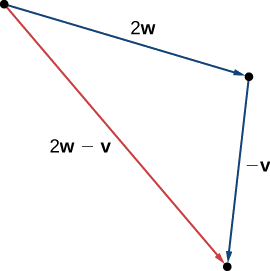
It is also appropriate here to discuss vector subtraction. We define \(\vecs{v}−\vecs{w}\) as \(\vecs{v}+(−\vecs{w})=\vecs{v}+(−1)\vecs{w}\). The vector \(\vecs{v}−\vecs{w}\) is called the vector difference. Graphically, the vector \(\vecs{v}−\vecs{w}\) is depicted by drawing a vector from the terminal point of \(\vecs{w}\) to the terminal point of \(\vecs{v}\).
In Figure \(\PageIndex{3 (a)}\), the initial point of \(\vecs{v}+\vecs{w}\) is the initial point of \(\vecs{v}\). The terminal point of \(\vecs{v}+\vecs{w}\) is the terminal point of \(\vecs{w}\). These three vectors form the sides of a triangle. It follows that the length of any one side is less than the sum of the lengths of the remaining sides. So we have
\[\|\vecs{v}+\vecs{w}\|≤\|\vecs{v}\|+\|\vecs{w}\|. \nonumber \]
This is known more generally as the triangle inequality. There is one case, however, when the resultant vector \(\vecs{v}+\vecs{w}\) has the same magnitude as the sum of the magnitudes of \(\vecs{v}\) and \(\vecs{w}\). This happens only when \(\vecs{v}\) and \(\vecs{w}\) have the same direction.
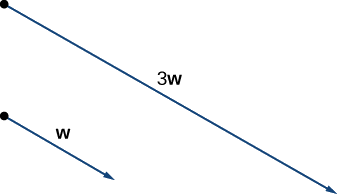
Given the vectors \(\vecs{v}\) and \(\vecs{w}\) shown below, we will sketch the vectors
(a) \(3\vecs{w}\), (b) \(\vecs{v}+\vecs{w}\), (c) \(2\vecs{v}−\vecs{w}\), and (d) \(2\vecs{w}−\vecs{v}\)
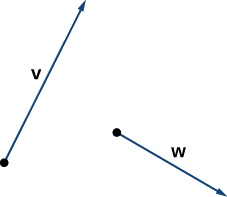
(a) The vector \(3\vecs{w}\) has the same direction as \(\vecs{w}\); it is three times as long as \(\vecs{w}\).
(b) Use either addition method to find \(\vecs{v}+\vecs{w}\).
(c) To find \(2\vecs{v}−\vecs{w}\), we can first rewrite the expression as \(2\vecs{v}+(−\vecs{w})\). Then we can draw the vector \(−\vecs{w}\), then add it to the vector \(2\vecs{v}\).
(d) To find \(2\vecs{w}−\vecs{v}\), we can first rewrite the expression as \(2\vecs{w}+(−\vecs{v})\). Then we can draw the vector \(−\vecs{v}\), then add it to the vector \(2\vecs{w}\).
Working with vectors in a plane is easier when we are working in a coordinate system. When the initial points and terminal points of vectors are given in Cartesian coordinates, computations become straightforward.
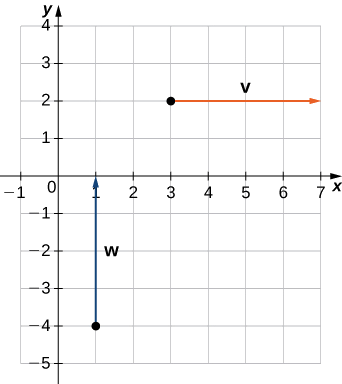
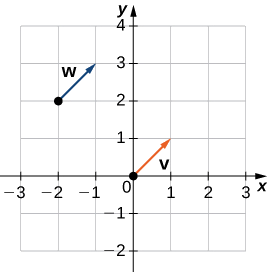
Are \(\vecs{v}\) and \(\vecs{w}\) equivalent vectors?
(a) \(\vecs{v}\) has initial point \((3,2)\) and terminal point \((7,2)\) while \(\vecs{w}\) has initial point \((1,−4)\) and terminal point \((1,0)\)
(b) \(\vecs{v}\) has initial point \((0,0)\) and terminal point \((1,1)\) while \(\vecs{w}\) has initial point \((−2,2)\) and terminal point \((−1,3)\)
Solution
(a) The vectors are each \(4\) units long, but they are oriented in different directions. So \(\boxed{\vecs{v}\text{ and }\vecs{w}\text{ are not equivalent}}\)
(b) It is clear these vectors have the same length and the same direction, so \(\boxed{\vecs{v}\text{ and }\vecs{w}\text{ are equivalent}}\)
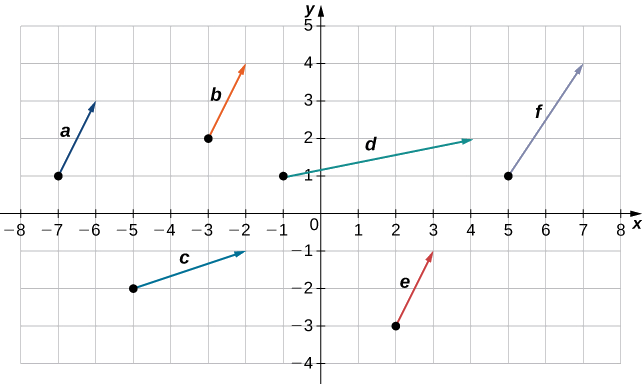
Which of the following vectors are equivalent?
Solution
Vectors \(\vecs{a}, \vecs{b}\), and \(\vecs{e}\) are equivalent, but no other pairs match in both direction and length.
We have seen how to plot a vector when we are given an initial point and a terminal point. However, because a vector can be placed anywhere in a plane, it may be easier to perform calculations with a vector when its initial point coincides with the origin. We call a vector with its initial point at the origin a standard-position vector. Because the initial point of any vector in standard position is known to be \((0,0)\), we can describe the vector by looking at the coordinates of its terminal point.
The vector with initial point \((0,0)\) and terminal point \((x,y)\) can be written in component form as
\[\vecs{v}=⟨x,y⟩ \nonumber \]
The scalars \(x\) (horizontal) and \(y\) (vertical) are the components of \(\vecs{v}\).
Recall that vectors are named with lowercase letters in bold type or by drawing an arrow over their name. We have also learned that we can name a vector by its component form, with the coordinates of its terminal point in angle brackets. However, when writing the component form of a vector, it is important to distinguish between \(⟨x,y⟩\) and \((x,y)\). The first ordered pair uses angle brackets to describe a vector, whereas the second uses parentheses to describe a point in a plane. The initial point of \(⟨x,y⟩\) is \((0,0)\); the terminal point of \(⟨x,y⟩\) is \((x,y)\).
When we have a vector not already in standard position, we can determine its component form in one of two ways. We can use a geometric approach, in which we sketch the vector in the coordinate plane, and then sketch an equivalent standard-position vector. Alternatively, we can find it algebraically, using the coordinates of the initial point and the terminal point. To find it algebraically, we subtract the \(x\)-coordinate of the initial point from the \(x\)-coordinate of the terminal point to get the \(x\)-component, and we subtract the \(y\)-coordinate of the initial point from the \(y\)-coordinate of the terminal point to get the \(y\)-component.
Let \(\vecs{v}\) be a vector with initial point \((x_i,y_i)\) and terminal point \((x_t,y_t)\). Then we can express \(\vecs{v}\) in component form as \(\vecs{v}=⟨x_t−x_i,y_t−y_i⟩\)
Express vector \(\vecs{v}\) with initial point \((−3,4)\) and terminal point \((1,2)\) in component form.
Solution:
This can be done geometrically:
1. Sketch the vector in the coordinate plane.
2. The terminal point is 4 units to the right and 2 units down from the initial point.
3. Find the point that is 4 units to the right and 2 units down from the origin.
4. In standard position, this vector has initial point \((0,0)\) and terminal point \((4,−2)\):
\(\vecs{v}=⟨4,−2⟩\)
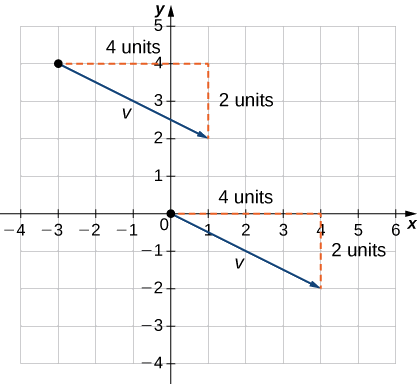
Or we can solve for \(\vecs{v}\) algebraically using the above formula:
\(\vecs{v}=⟨x_t−x_i,y_t−y_i⟩=⟨1−(−3),2−4⟩=⟨4,−2⟩\)
To find the magnitude of a vector, we calculate the distance between its initial point and its terminal point. The magnitude of vector \(\vecs{v}=⟨x,y⟩\) is denoted \(\|\vecs{v}\|,\) or \(|\vecs{v}|\), and can be computed using the formula
\[\|\vecs{v}\|=\sqrt{x^2+y^2} \nonumber \]
Note that because this vector is written in component form, it is equivalent to a vector in standard position, with its initial point at the origin and terminal point \((x,y)\). Thus, it suffices to calculate the magnitude of the vector in standard position. Using the distance formula to calculate the distance between initial point \((0,0)\) and terminal point \((x,y)\), we have
\[\|\vecs{v}\|=\sqrt{(x−0)^2+(y−0)^2}=\sqrt{x^2+y^2} \nonumber \]
Based on this formula, it is clear that for any vector \(\vecs{v}, \|\vecs{v}\|≥0,\) and \(\|\vecs{v}\|=0\) if and only if \(\vecs{v}=\vecs{0}\).
The magnitude of a vector can also be derived using the Pythagorean theorem, as in the following figure.
We have defined scalar multiplication and vector addition geometrically. Expressing vectors in component form allows us to perform these same operations algebraically.
Let \(\vecs{v}=⟨x_1,y_1⟩\) and \(\vecs{w}=⟨x_2,y_2⟩\) be vectors, and let \(k\) be a scalar.
- Scalar multiplication: \[k\vecs{v}=⟨kx_1,ky_1⟩ \nonumber \]
- Vector addition: \[\vecs{v}+\vecs{w}=⟨x_1,y_1⟩+⟨x_2,y_2⟩=⟨x_1+x_2,y_1+y_2⟩ \nonumber \]
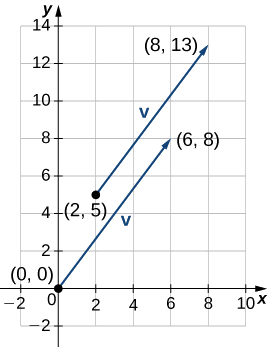
Let \(\vecs{v}\) be the vector with initial point \((2,5)\) and terminal point \((8,13)\), and let \(\vecs{w}=⟨−2,4⟩\).
(a) Express \(\vecs{v}\) in component form and find \(\|\vecs{v}\|\)
(b) Find \(\vecs{v}+\vecs{w}\)
(c) Find \(3\vecs{v}\)
(d) Find \(\vecs{v}−2\vecs{w}\)
Solution
(a) To place the initial point of \(\vecs{v}\) at the origin, we must translate the vector 2 units to the left and 5 units down.
Using the algebraic method, we can express \(\vecs{v}\) as \(\vecs{v}=⟨8−2,13−5⟩=\boxed{⟨6,8⟩}\):
\(\|\vecs{v}\|=\sqrt{6^2+8^2}=\sqrt{36+64}=\sqrt{100}=\boxed{10}\)
(b) To find \(\vecs{v}+\vecs{w}\), add the \(x\)-components and the \(y\)-components separately:
\(\vecs{v}+\vecs{w}=⟨6,8⟩+⟨−2,4⟩=\boxed{⟨4,12⟩}\)
(c) To find \(3\vecs{v}\), multiply \(\vecs{v}\) by the scalar \(k=3\):
\(3\vecs{v}=3⋅⟨6,8⟩=⟨3⋅6,3⋅8⟩=\boxed{⟨18,24⟩}\)
(d) To find \(\vecs{v}−2\vecs{w}\), find \(−2\vecs{w}\) and add it to \(\vecs{v}:\)
\(\vecs{v}−2\vecs{w}=⟨6,8⟩−2⋅⟨−2,4⟩=⟨6,8⟩+⟨4,−8⟩=\boxed{⟨10,0⟩}\)
Now that we have established the basic rules of vector arithmetic, we can state the properties of vector operations. We will prove two of these properties. The others can be proved in a similar manner.
Let \(\vecs{u}, \, \vecs{v}\), and \(\vecs{w}\) be vectors in a plane. Let \(r\) and \(s\) be scalars.
- Commutative property \[\vecs{u}+\vecs{v}=\vecs{v}+\vecs{u} \nonumber \]
- Associative property \[(\vecs{u}+\vecs{v})+\vecs{w}=\vecs{u}+(\vecs{v}+\vecs{w}) \nonumber \]
- Additive identity property \[\vecs{u}+\vecs{0}=\vecs{u} \nonumber \]
- Additive inverse property \[\vecs{u}+(−\vecs{u})=\vecs{0} \nonumber \]
- Associativity of scalar multiplication \[r(s\vecs{u})=(rs)\vecs{u} \nonumber \]
- Distributive property \[(r+s)\vecs{u}=r\vecs{u}+s\vecs{u} \nonumber \]
- Distributive property \[r(\vecs{u}+\vecs{v})=r\vecs{u}+r\vecs{v} \nonumber \]
- Identity and zero properties \[1\vecs{u}=\vecs{u}, \, 0\vecs{u}=\vecs{0} \nonumber \]
Let \(\vecs{u}=⟨x_1,y_1⟩\) and \(\vecs{v}=⟨x_2,y_2⟩.\) Apply the commutative property for real numbers:
\[ \begin{align*} \vecs{u}+\vecs{v} =⟨x_1+x_2,y_1+y_2⟩ \\[4pt] = ⟨x_2+x_1,y_2+y_1⟩ \\[4pt] = \vecs{v}+\vecs{u} \end{align*}\]
Apply the distributive property for real numbers:
\[ \begin{align*} r(\vecs{u}+\vecs{v}) =r⋅⟨x_1+x_2,y_1+y_2⟩ \\[4pt] =⟨r(x_1+x_2),r(y_1+y_2)⟩ \\[4pt] = ⟨rx_1+rx_2,ry_1+ry_2⟩ \\[4pt] = ⟨rx_1,ry_1⟩+⟨rx_2,ry_2⟩ \\[4pt] = r\vecs{u}+r\vecs{v} \end{align*}\]
We have found the components of a vector given its initial and terminal points. In some cases, we may only have the magnitude and direction of a vector, not the points. For these vectors, we can identify the horizontal and vertical components using trigonometry.
Consider the angle \(θ\) formed by the vector \(\vecs{v}\) and the positive \(x\)-axis. We can see from the triangle that the components of vector \(\vecs{v}\) are \(⟨\|\vecs{v}\| \cos(θ), \, \|\vecs{v}\| \sin (θ)⟩\). Therefore, given an angle and the magnitude of a vector, we can use the cosine and sine of the angle to find the components of the vector.
A unit vector is a vector with magnitude \(1\). For any nonzero vector \(\vecs{v}\), we can use scalar multiplication to find a unit vector \(\vecs{u}\) that has the same direction as \(\vecs{v}\). To do this, we multiply the vector by the reciprocal of its magnitude:
\[\vecs{u}=\dfrac{1}{\|\vecs{v}\|} \vecs{v} \nonumber \]
Recall that when we defined scalar multiplication, we noted that \(\|k\vecs{v}\| =|k|⋅\|\vecs{v}\| \). For \(\vecs{u}=\dfrac{1}{\|\vecs{v}\| }\vecs{v}\), it follows that \(\|\vecs{u}\| =\dfrac{1}{\|\vecs{v}\| }(\|\vecs{v}\| )=1\). We say that \(\vecs{u}\) is the unit vector in the direction of \(\vecs{v}\). The process of using scalar multiplication to find a unit vector with a given direction is called normalization.
Let \(\vecs{v}=⟨1,2⟩\)
(a) Find a unit vector with the same direction as \(\vecs{v}\)
(b) Find a vector \(\vecs{w}\) with the same direction as \(\vecs{v}\) such that \(\|\vecs{w}\|=7\)
Solution:
(a) First, find the magnitude of \(\vecs{v}\), then divide the components of \(\vecs{v}\) by the magnitude:
\[\|\vecs{v}\|=\sqrt{1^2+2^2}=\sqrt{1+4}=\sqrt{5} \nonumber \]
\[\vecs{u}=\dfrac{1}{\|\vecs{v}\|}\vecs{v}=\dfrac{1}{\sqrt{5}}⟨1,2⟩=\boxed{\left\langle \dfrac{1}{\sqrt{5}},\dfrac{2}{\sqrt{5}}\right\rangle} \nonumber \]
(b) The vector \(\vecs{u}\) is in the same direction as \(\vecs{v}\) and \(\|\vecs{u}\|=1\). Use scalar multiplication to increase the length of \(\vecs{u}\) without changing direction:
\[\vecs{w}=7\vecs{u}=7\left\langle \dfrac{1}{\sqrt{5}},\dfrac{2}{\sqrt{5}}\right\rangle=\boxed{\left\langle\dfrac{7}{\sqrt{5}},\dfrac{14}{\sqrt{5}}\right\rangle} \nonumber\]
We have seen how convenient it can be to write a vector in component form. Sometimes, though, it is more convenient to write a vector as a sum of a horizontal vector and a vertical vector. To make this easier, let’s look at standard unit vectors. The standard unit vectors are the vectors \(\hat{\mathbf i}=⟨1,0⟩\) and \(\hat{\mathbf j}=⟨0,1⟩\)
By applying the properties of vectors, it is possible to express any vector in terms of \(\hat{\mathbf i}\) and \(\hat{\mathbf j}\) in what we call a linear combination:
\[\vecs{v}=⟨x,y⟩=⟨x,0⟩+⟨0,y⟩=x⟨1,0⟩+y⟨0,1⟩=x\hat{\mathbf i}+y\hat{\mathbf j} \nonumber \]
Thus, \(\vecs{v}\) is the sum of a horizontal vector with magnitude \(x\), and a vertical vector with magnitude \(y\), as in Figure \(\PageIndex{17}\).
Just like two-dimensional vectors, three-dimensional vectors are quantities with both magnitude and direction, and they are represented by directed line segments (arrows). With a three-dimensional vector, we use a three-dimensional arrow.
Three-dimensional vectors can also be represented in component form. The notation \(\vecs{v}=⟨x,y,z⟩\) is a natural extension of the two-dimensional case, representing a vector with the initial point at the origin, \((0,0,0)\), and terminal point \((x,y,z)\). The zero vector is \(\vecs{0}=⟨0,0,0⟩\). So, for example, the three dimensional vector \(\vecs{v}=⟨2,4,1⟩\) is represented by a directed line segment from point \((0,0,0)\) to point \((2,4,1)\).
Vector addition and scalar multiplication are defined analogously to the two-dimensional case. If \(\vecs{v}=⟨x_1,y_1,z_1⟩\) and \(\vecs{w}=⟨x_2,y_2,z_2⟩\) are vectors, and \(k\) is a scalar, then
\[\vecs{v}+\vecs{w}=⟨x_1+x_2,y_1+y_2,z_1+z_2⟩ \nonumber \]
and
\[k\vecs{v}=⟨kx_1,ky_1,kz_1⟩ \nonumber \]
If \(k=−1,\) then \(k\vecs{v}=(−1)\vecs{v}\) is written as \(−\vecs{v}\), and vector subtraction is defined by \(\vecs{v}−\vecs{w}=\vecs{v}+(−\vecs{w})=\vecs{v}+(−1)\vecs{w}\).
The standard unit vectors extend easily into three dimensions as well, \(\hat{\mathbf i}=⟨1,0,0⟩\), \(\hat{\mathbf j}=⟨0,1,0⟩\), and \(\hat{\mathbf k}=⟨0,0,1⟩\), and we use them in the same way we used the standard unit vectors in two dimensions. Thus, we can represent a vector in \(ℝ^3\) in the following ways:
\[\vecs{v}=⟨x,y,z⟩=x\hat{\mathbf i}+y\hat{\mathbf j}+z\hat{\mathbf k} \nonumber \]
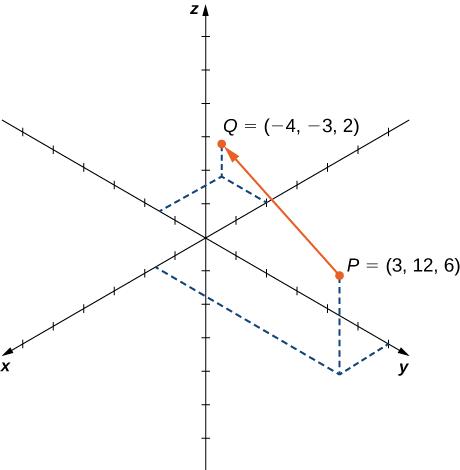
Let \(\vecd{PQ}\) be the vector with initial point \(P=(3,12,6)\) and terminal point \(Q=(−4,−3,2)\) as shown below. Express \(\vecd{PQ}\) in both component form and using standard unit vectors.
Solution
In component form,
\[\begin{align*} \vecd{PQ} =⟨x_2−x_1,y_2−y_1,z_2−z_1⟩ \\[4pt] =⟨−4−3,−3−12,2−6⟩ \\[4pt] =⟨−7,−15,−4⟩ \end{align*}\]
In standard unit form,
\[\vecd{PQ}=−7\hat{\mathbf i}−15\hat{\mathbf j}−4\hat{\mathbf k} \nonumber \]
As described earlier, vectors in three dimensions behave in the same way as vectors in a plane. The geometric interpretation of vector addition, for example, is the same in both two- and three-dimensional space.
We have already seen how some of the algebraic properties of vectors, such as vector addition and scalar multiplication, can be extended to three dimensions. Other properties can be extended in similar fashion. They are summarized here for our reference.
Let \(\vecs{v}=⟨x_1,y_1,z_1⟩\) and \(\vecs{w}=⟨x_2,y_2,z_2⟩\) be vectors, and let \(k\) be a scalar.
- Scalar multiplication: \[k\vecs{v}=⟨kx_1,ky_1,kz_1⟩ \nonumber \]
- Vector addition: \[\vecs{v}+\vecs{w}=⟨x_1,y_1,z_1⟩+⟨x_2,y_2,z_2⟩=⟨x_1+x_2,y_1+y_2,z_1+z_2⟩ \nonumber \]
- Vector subtraction: \[\vecs{v}−\vecs{w}=⟨x_1,y_1,z_1⟩−⟨x_2,y_2,z_2⟩=⟨x_1−x_2,y_1−y_2,z_1−z_2⟩ \nonumber \]
- Vector magnitude: \[\|\vecs{v}\|=\sqrt{x_1^2+y_1^2+z_1^2} \nonumber \]
- Unit vector in the direction of \(\vecs{v}\): \[\dfrac{1}{\|\vecs{v}\|}\vecs{v}=\dfrac{1}{\|\vecs{v}\|}⟨x_1,y_1,z_1⟩=\left\langle\dfrac{x_1}{\|\vecs{v}\|},\dfrac{y_1}{\|\vecs{v}\|},\dfrac{z_1}{\|\vecs{v}\|}\right\rangle, \quad \text{if} \, \vecs{v}≠\vecs{0} \nonumber \]
We have seen that vector addition in two dimensions satisfies the commutative, associative, and additive inverse properties. These properties of vector operations are valid for three-dimensional vectors as well. Scalar multiplication of vectors satisfies the distributive property, and the zero vector acts as an additive identity. The proofs to verify these properties in three dimensions are straightforward extensions of the proofs in two dimensions.
Let \(\vecs{v}=⟨−2,9,5⟩\) and \(\vecs{w}=⟨1,−1,0⟩\). Find the following vectors.
(a) \(3\vecs{v}−2\vecs{w}\)
(b) \(5\|\vecs{w}\|\)
(c) \(\|5 \vecs{w}\|\)
(d) A unit vector in the direction of \(\vecs{v}\)
Solution
(a) First, use scalar multiplication of each vector, then subtract:
\[\begin{align*} 3\vecs{v}−2\vecs{w} =3⟨−2,9,5⟩−2⟨1,−1,0⟩ \\[4pt] =⟨−6,27,15⟩−⟨2,−2,0⟩ \\[4pt] =⟨−6−2,27−(−2),15−0⟩ \\[4pt] = \boxed{⟨−8,29,15⟩ }\end{align*}\]
(b) Write the equation for the magnitude of the vector, then use scalar multiplication:
\[5\|\vecs{w}\|=5\sqrt{1^2+(−1)^2+0^2}=\boxed{5\sqrt{2}} \nonumber \]
(c) First, use scalar multiplication, then find the magnitude of the new vector. Note that the result is the same as for part b:
\[\|5 \vecs{w}\|=∥⟨5,−5,0⟩∥=\sqrt{5^2+(−5)^2+0^2}=\sqrt{50}=\boxed{5\sqrt{2}} \nonumber \]
(d) Recall that to find a unit vector in two dimensions, we divide a vector by its magnitude. The procedure is the same in three dimensions:
\[\begin{align*} \dfrac{\vecs{v}}{\|\vecs{v}\|} =\dfrac{1}{\|\vecs{v}\|}⟨−2,9,5⟩ \\[4pt] =\dfrac{1}{\sqrt{(−2)^2+9^2+5^2}}⟨−2,9,5⟩ \\[4pt] =\dfrac{1}{\sqrt{110}}⟨−2,9,5⟩ \\[4pt] =\boxed{\left\langle\dfrac{−2}{\sqrt{110}},\dfrac{9}{\sqrt{110}},\dfrac{5}{\sqrt{110}}\right\rangle }\end{align*}\]
This page titled 1.1: Vectors in the Plane and Space was last modified on Tue, 14 Apr 2026 22:03:02 GMT and is shared under a CC BY-NC 4.0 license and was authored, remixed, and/or curated by Kenn Huber via source content that was edited to the style and standards of the LibreTexts platform.
The book could not be loaded just now.