Opening the book…
- Find the matrix of rotations in \(\mathbb{R}^2\) and \(\mathbb{R}^3\) and determine the action of each on a vector in \(\mathbb{R}^2\) and \(\mathbb{R}^3\).
- Find the matrix of reflections in \(\mathbb{R}^2\) and \(\mathbb{R}^3\) and determine the action of each on a vector in \(\mathbb{R}^2\) and \(\mathbb{R}^3\).
- Find the matrix of projections in \(\mathbb{R}^2\) and \(\mathbb{R}^3\) and determine the action of each on a vector in \(\mathbb{R}^2\) and \(\mathbb{R}^3\).
- Find the matrix of other linear transformation in \(\mathbb{R}^2\) and \(\mathbb{R}^3\) and determine the action of each on a vector in \(\mathbb{R}^2\) and \(\mathbb{R}^3\), such as dilations, contractions, expansions, compressions, and shears.
In this section, we will examine some special examples of linear transformations in \(\mathbb{R}^2\) and \(\mathbb{R}^3\) including rotations, reflections and projections. We will use the geometric descriptions of vector addition and scalar multiplication discussed earlier to show these are examples of linear transformations.
Rotations
First, consider a transformation given by a rotation \(T\). Why is such a transformation linear? Consider the following picture which illustrates a rotation in \(\mathbb{R}^2\). Let \(\vec{u},\vec{v}\) denote vectors.

Let’s consider how to obtain \(T\left ( \vec{u}+\vec{v}\right )\). Simply, you add \(T (\vec{u})\) and \(T(\vec{v})\). Here is why. If you add \(T(\vec{u})\) to \(T(\vec{v})\) you get the diagonal of the parallelogram determined by \(T(\vec{u})\) and \(T(\vec{v})\), as this action is our usual vector addition. Now, suppose we first add \(\vec{u}\) and \(\vec{v}\), and then apply the transformation \(T\) to \(\vec{u}+\vec{v}\). Hence, we find \(T( \vec{u}+\vec{v})\). As shown in the diagram, this will result in the same vector. In other words, \(T(\vec{u}+\vec{v}) = T(\vec{u}) + T(\vec{v})\).
This is because the rotation preserves all angles between the vectors as well as their lengths. In particular, it preserves the shape of this parallelogram. Thus both \(T\left (\vec{u}\right)+T\left (\vec{v}\right )\) and \(T\left (\vec{u}+\vec{v}\right )\) give the same vector. It follows that \(T\) distributes across addition of the vectors of \(\mathbb{R}^{2}\).
Similarly, if \(k\) is a scalar, it follows that \(T\left (k\vec{u}\right )=kT\left (\vec{u}\right )\). Thus rotations are an example of a linear transformation by Definition 5.1.1.
The following theorem gives the matrix of a linear transformation which rotates all vectors through an angle of \(\theta\).
Let \(R_{\theta}: \mathbb{R}^2 \to \mathbb{R}^2\) be a linear transformation given by rotating vectors through an angle of \(\theta\). Then the matrix \(A\) of \(R_{\theta}\) is given by \[\left [ \begin{array}{rr} \cos \left ( \theta \right ) & -\sin \left ( \theta \right ) \\ \sin \left ( \theta \right ) & \cos \left ( \theta \right ) \end{array} \right ]\nonumber \]
- Proof
-
Let \(\vec{e}_{1} = \left [ \begin{array}{r} 1 \\ 0 \end{array} \right ]\) and \(\vec{e}_{2} = \left [ \begin{array}{r} 0 \\ 1 \end{array} \right ] .\) These identify the geometric vectors which point along the positive \(x\) axis and positive \(y\) axis as shown.

Figure \(\PageIndex{2}\) Standard basis vectors \(\vec{e_1},\vec{e_2}\) and the result of rotating them through angle \(\theta\) (CC BY-NC-SA 4.0; Kuttler via A First Course in LINEAR ALGEBRA) From Theorem 5.2.2, we need to find \(R_{\theta}(\vec{e}_{1})\) and \(R_{\theta}(\vec{e}_{2}),\) and use these as the columns of the matrix \(A\) of \(T\). We can use \(\cos, \sin\) of the angle \(\theta\) to find the coordinates of \(R_{\theta}(\vec{e}_{1})\) as shown in the above picture. The coordinates of \(R_{\theta}(\vec{e}_{2})\) also follow from trigonometry. Thus \[R_{\theta}(\vec{e}_{1})=\left [ \begin{array}{r} \cos \theta \\ \sin \theta \end{array} \right ] ,R_{\theta}(\vec{e}_{2})=\left [ \begin{array}{r} -\sin \theta \\ \cos \theta \end{array} \right ]\nonumber \] Therefore, from Theorem 5.2.2, \[A=\left [ \begin{array}{rr} \cos \theta & -\sin \theta \\ \sin \theta & \cos \theta \end{array} \right ]\nonumber \]
We can also prove this algebraically without the use of the above picture. The definition of \(\left [ \cos \left [ \theta \right ] ,\sin \left [ \theta \right ] \right ]\) is as the coordinates of the point of \(R_{\theta}(\vec{e}_{1})\). Now the point of the vector \(\vec{e}_{2}\) is exactly \(\pi /2\) further along the unit circle from the point of \(\vec{e}_{1}\), and therefore after rotation through an angle of \(\theta\) the coordinates \(x\) and \(y\) of the point of \(R_{\theta}(\vec{e}_{2})\) are given by \[\left [ x,y\right ] =\left [ \cos \left [ \theta +\pi /2\right ] ,\sin \left [ \theta +\pi /2\right ] \right ] =\left [ -\sin \theta ,\cos \theta \right ]\nonumber \]
Consider the following example.
Let \(R_{\frac{\pi}{2}}: \mathbb{R}^2 \to \mathbb{R}^2\) denote rotation through \(\frac{\pi}{2} \). Find the matrix of \(R_{\frac{\pi}{2}}\). Then, find \(R_{\frac{\pi}{2}} (\vec{x})\) where \(\vec{x} = \left [ \begin{array}{r} 1 \\ -2 \end{array} \right ]\).
Solution
By Theorem \(\PageIndex{1}\), the matrix of \(R_{\frac{\pi}{2}}\) is given by \[\left [ \begin{array}{rr} \cos \left ( \theta \right ) & -\sin \left ( \theta \right ) \\ \sin \left ( \theta \right ) & \cos \left ( \theta \right ) \end{array} \right ] = \left [ \begin{array}{rr} \cos \left ( \pi/2 \right ) & -\sin \left ( \pi/2 \right ) \\ \sin \left ( \pi/2 \right ) & \cos \left ( \pi/2 \right ) \end{array} \right ] = \left [ \begin{array}{rr} 0 & -1 \\ 1 & 0 \end{array} \right ]\nonumber \]
To find \(R_{\frac{\pi}{2}} (\vec{x})\), we multiply the matrix of \(R_{\frac{\pi}{2}}\) by \(\vec{x}\) as follows \[\left [ \begin{array}{rr} 0 & -1 \\ 1 & 0 \end{array} \right ] \left [ \begin{array}{r} 1 \\ -2 \end{array} \right ] = \left [ \begin{array}{r} 2 \\ 1 \end{array} \right ]\nonumber \]
Watch the accompanying video for a visual demonstration of the this concept.
- Video Length: 3 minutes 53 seconds.
- Context: This video demonstrates the transformation matrix for a \(\mathbb{R}^2\) rotation: Write a standard matrix for a \( \mathbb{R}^2 \to \mathbb{R}^2 \) transformation that rotates points \( \frac{2\pi}{3}\) radians about the origin.
We now look at an example of a linear transformation involving two angles.
Find the matrix of the linear transformation which is obtained by first rotating all vectors through an angle of \(\phi\) and then through an angle \(\theta .\) Hence the linear transformation rotates all vectors through an angle of \(\theta +\phi .\)
Solution
Let \(R_{\theta +\phi }\) denote the linear transformation which rotates every vector through an angle of \(\theta +\phi .\) Then to obtain \(R_{\theta +\phi },\) we first apply \(R_{\phi }\) and then \(R_{\theta }\) where \(R_{\phi }\) is the linear transformation which rotates through an angle of \(\phi\) and \(R_{\theta }\) is the linear transformation which rotates through an angle of \(\theta\). Denoting the corresponding matrices by \(A_{\theta +\phi }\), \(A_{\phi },\) and \(A_{\theta },\) it follows that for every \(\vec{u}\) \[R_{\theta +\phi }\left (\vec{u}\right )=A_{\theta +\phi }\vec{u}=A_{\theta }A_{\phi }\vec{u} = R_{\theta }R_{\phi } \left (\vec{u}\right )\nonumber \] Notice the order of the matrices here!
Consequently, you must have \[\begin{aligned} A_{\theta +\phi } &=\left [ \begin{array}{cc} \cos \left ( \theta +\phi \right ) & -\sin \left ( \theta +\phi \right ) \\ \sin \left ( \theta +\phi \right ) & \cos \left ( \theta +\phi \right ) \end{array} \right ]\\ &=\left [ \begin{array}{cc} \cos \theta & -\sin \theta \\ \sin \theta & \cos \theta \end{array} \right ] \left [ \begin{array}{cc} \cos \phi & -\sin \phi \\ \sin \phi & \cos \phi \end{array} \right ] =A_{\theta }A_{\phi } \end{aligned}\]
The usual matrix multiplication yields \[\begin{aligned} A_{\theta +\phi } &= \left [ \begin{array}{cc} \cos \left ( \theta +\phi \right ) & -\sin \left ( \theta +\phi \right ) \\ \sin \left ( \theta +\phi \right ) & \cos \left ( \theta +\phi \right ) \end{array} \right ] \\ &=\left [ \begin{array}{cc} \cos \theta \cos \phi -\sin \theta \sin \phi & -\cos \theta \sin \phi -\sin \theta \cos \phi \\ \sin \theta \cos \phi +\cos \theta \sin \phi & \cos \theta \cos \phi -\sin \theta \sin \phi \end{array} \right ] \\ &= A_{\theta }A_{\phi } \end{aligned}\]
Don’t these look familiar? They are the usual trigonometric identities for the sum of two angles derived here using linear algebra concepts.
Here we have focused on rotations in two dimensions. However, you can consider rotations and other geometric concepts in any number of dimensions. This is one of the major advantages of linear algebra. You can break down a difficult geometrical procedure into small steps, each corresponding to multiplication by an appropriate matrix. Then by multiplying the matrices, you can obtain a single matrix which can give you numerical information on the results of applying the given sequence of simple procedures.
Reflections
Linear transformations which reflect vectors across a line are a second important type of transformations in \(\mathbb{R}^2\). Consider the following theorem.
Let \(Q_m: \mathbb{R}^2 \to \mathbb{R}^2\) be a linear transformation given by reflecting vectors over the line \(y=mx\). Then the matrix of \(Q_m\) is given by \[\frac{1}{1+m^2} \left [ \begin{array}{cc} 1-m^2 & 2m \\ 2m & m^2-1 \end{array} \right ]\nonumber \]
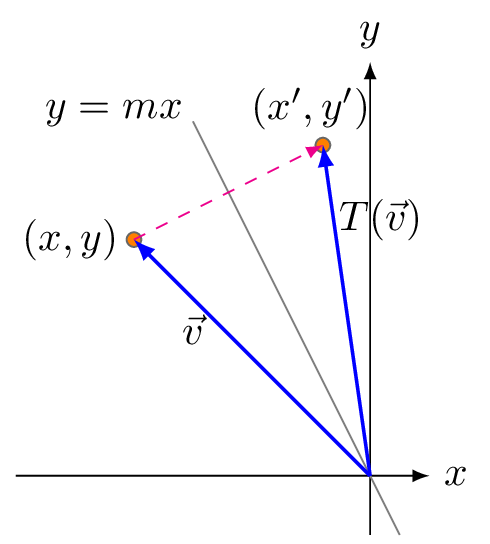
Consider the following example.
Let \(Q_2: \mathbb{R}^2 \to \mathbb{R}^2\) denote reflection over the line \(y=2x\). Then \(Q_2\) is a linear transformation. Find the matrix of \(Q_2\). Then, find \(Q_2 (\vec{x})\) where \(\vec{x} = \left [ \begin{array}{r} 1 \\ -2 \end{array} \right ]\).
Solution
By Theorem \(\PageIndex{2}\), the matrix of \(Q_2\) is given by \[\frac{1}{1+m^2} \left [ \begin{array}{cc} 1-m^2 & 2m \\ 2m & m^2-1 \end{array} \right ] = \frac{1}{1+(2)^2} \left [ \begin{array}{cc} 1-(2)^2 & 2(2) \\ 2(2) & (2)^2-1 \end{array} \right ] = \frac{1}{5} \left [ \begin{array}{rr} -3 & 8 \\ 8 & 3 \end{array} \right ]\nonumber \]
To find \(Q_2(\vec{x})\) we multiply \(\vec{x}\) by the matrix of \(Q_2\) as follows: \[\frac{1}{5} \left [ \begin{array}{rr} -3 & 8 \\ 8 & 3 \end{array} \right ] \left [ \begin{array}{r} 1 \\ -2 \end{array} \right ] = \left [ \begin{array}{r} - \frac{19}{5} \\ \frac{2}{5} \end{array} \right ]\nonumber \]
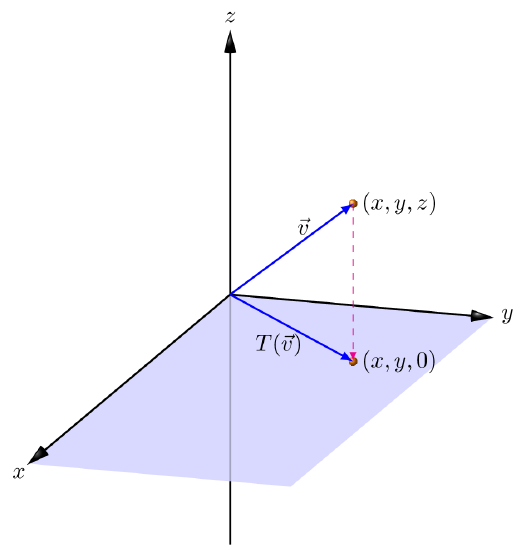
We can also consider transformations that reflect a vector in \(\mathbb{R}^3\) through a plane that passes through the origin. Consider, for example, reflection through the \(XY\)-plane (the plane \(z = 0\)). As shown in the illustration below, this reflection is given by the transformation \(T(x, y, z) = (x, y, -z)\). The matrix of this transformation would be \(A= \left[\begin{array}{rrr} 1 & 0 & 0 \\ 0 & 1 & 0 \\ 0 & 0 & -1 \end{array} \right]\)

Consider the following example which incorporates a reflection as well as a rotation of vectors.
Find the matrix of the linear transformation which is obtained by first rotating all vectors through an angle of \(\pi /6\) and then reflecting through the \(x\) axis.
Solution
By Theorem \(\PageIndex{1}\), the matrix of the transformation which involves rotating through an angle of \(\pi /6\) is \[\left [ \begin{array}{rr} \cos \left (\pi /6\right) & -\sin \left (\pi /6\right) \\ \sin \left (\pi /6\right) & \cos \left (\pi /6\right) \end{array} \right ] =\left [ \begin{array}{cc} \frac{1}{2}\sqrt{3} & - \frac{1}{2} \\ \frac{1}{2} & \frac{1}{2}\sqrt{3} \end{array} \right ]\nonumber \]
Reflecting across the \(x\) axis is the same action as reflecting vectors over the line \(\vec{y}=m\vec{x}\) with \(m=0\). By Theorem \(\PageIndex{2}\), the matrix for the transformation which reflects all vectors through the \(x\) axis is \[\frac{1}{1+m^2} \left [ \begin{array}{cc} 1-m^2 & 2m \\ 2m & m^2-1 \end{array} \right ] = \frac{1}{1+(0)^2} \left [ \begin{array}{cc} 1-(0)^2 & 2(0) \\ 2(0) & (0)^2-1 \end{array} \right ] = \left [ \begin{array}{rr} 1 & 0 \\ 0 & -1 \end{array} \right ]\nonumber \]
Therefore, the matrix of the linear transformation which first rotates through \(\pi /6\) and then reflects through the \(x\) axis is given by \[\left [ \begin{array}{rr} 1 & 0 \\ 0 & -1 \end{array} \right ] \left [ \begin{array}{rr} \frac{1}{2}\sqrt{3} & - \frac{1}{2} \\ \frac{1}{2} & \frac{1}{2}\sqrt{3} \end{array} \right ] = \ \left [ \begin{array}{rr} \frac{1}{2}\sqrt{3} & - \frac{1}{2} \\ - \frac{1}{2} & - \frac{1}{2}\sqrt{3} \end{array} \right ]\nonumber \]
Projections
Next consider the map \(\vec{v}\)\(\mapsto\) \(\mathrm{proj}_{\vec{u}}\left( \vec{v}\right)\) which takes a vector and transforms it to its projection onto a given vector \(\vec{u}\). It turns out that this map is linear, a result which follows from the properties of the dot product. This is shown as follows. \[\begin{aligned} \mathrm{proj}_{\vec{u}}\left( k \vec{v}+ p \vec{w}\right) &=\left( \frac{(k \vec{v}+ p \vec{w})\bullet \vec{u}}{ \vec{u}\bullet \vec{u}}\right) \vec{u} \\ &= k \left( \frac{ \vec{v}\bullet \vec{u}}{\vec{u}\bullet \vec{u}}\right) \vec{u}+p \left( { 0.05in}\frac{\vec{w}\bullet \vec{u}}{\vec{u}\bullet \vec{u}}\right) \vec{u} \\ &= k \; \mathrm{proj}_{\vec{u}}\left( \vec{v}\right) +p \; \mathrm{proj} _{\vec{u}}\left( \vec{w}\right) \end{aligned}\]
Let \(\vec{u} = \left[\begin{array}{r} 1 \\ 2 \\ 3 \end{array} \right]\) and let \(T\) be the projection map \(T: \mathbb{R}^3 \mapsto \mathbb{R}^3\) defined by \[T(\vec{v}) = \mathrm{proj}_{\vec{u}}\left( \vec{v}\right)\nonumber \] for any \(\vec{v} \in \mathbb{R}^3\).
- Does this transformation come from multiplication by a matrix?
- If so, what is the matrix?
Solution
- First, we have just seen that \(T (\vec{v}) = \mathrm{proj}_{\vec{u}}\left( \vec{v}\right)\) is linear. Therefore, we can find a matrix \(A\) such that \(T(\vec{x}) = A\vec{x}\).
- The columns of the matrix for \(T\) are defined above as \(T(\vec{e}_{i})\). It follows that \(T(\vec{e}_{i}) = \mathrm{proj} _{\vec{u}}\left( \vec{e}_{i}\right)\) gives the \(i^{th}\) column of the desired matrix. Therefore, we need to find \[\mathrm{proj}_{\vec{u}}\left( \vec{e}_{i}\right) = \left( \frac{\vec{e}_{i}\bullet \vec{u}}{\vec{u}\bullet \vec{u}}\right) \vec{u}\nonumber \] For the given vector \(\vec{u}\), this implies the columns of the desired matrix are \[ \frac{1}{14}\left[\begin{array}{r} 1 \\ 2 \\ 3 \end{array} \right] , \frac{2}{14}\left[\begin{array}{r} 1 \\ 2 \\ 3 \end{array} \right] , \frac{3}{14}\left[\begin{array}{r} 1 \\ 2 \\ 3 \end{array} \right]\nonumber \] which you can verify. Hence the matrix of \(T\) is \[ \frac{1}{14}\left[\begin{array}{rrr} 1 & 2 & 3 \\ 2 & 4 & 6 \\ 3 & 6 & 9 \end{array} \right]\nonumber\]
Let's consider a linear transformation on \(\mathbb{R}^2\) that projects a vector \(vec v\) onto the line \(y=mx\).
Let \(P_m: \mathbb{R}^2 \to \mathbb{R}^2\) be a linear transformation given by projecting vectors on to the line \(y=mx\). Then the matrix of \(P_m\) is given by \[\frac{1}{1+m^2} \left [ \begin{array}{cc} 1 & m \\ m & m^2 \end{array} \right ]\nonumber \]

Projections do not have to be onto a vector. In \( \mathbb{R}^3\), we can project vectors onto a plane that passes through the origin also. Consider, for example, projection on to the \(XY\)-plane (the plane \(z = 0\)). As shown in the illustration below, this reflection is given by the transformation \(T(x, y, z) = (x, y, 0)\). The matrix of this transformation would be \(A= \left[\begin{array}{rrr} 1 & 0 & 0 \\ 0 & 1 & 0 \\ 0 & 0 & 0 \end{array} \right]\)
Dilations and Contractions
A dilation is a linear transformation that scales all vectors away from the origin by a factor \( k \), where \( k > 1 \). This transformation enlarges objects in space while maintaining their relative proportions and the origin as a fixed point.
Mathematically, if \( T \) is a dilation transformation, then for any vector \( \vec{v} \),
\[
T(\vec{v}) = k\vec{v}, \quad \text{where } k > 1.
\]
A contraction is a linear transformation that scales all vectors toward the origin by a factor \( k \), where \( 0 < k < 1 \). This transformation shrinks objects while keeping the origin fixed.
Mathematically, for a contraction transformation,
\[
T(\vec{v}) = k\vec{v}, \quad \text{where } 0 < k < 1.
\]
Below are visual representations of a dilation in \(\mathbb{R}^2\) and a contraction in \(\mathbb{R}^3\).


Expansions and Compressions
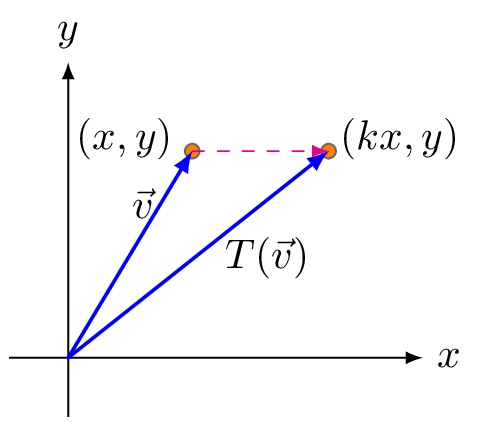
An expansion along a specific axis increases the magnitude of a vector’s component along that axis by a factor \( k \), where \( k > 1 \), while leaving the other coordinate(s) unchanged.
An compression along a specific axis decreases the magnitude of a vector’s component along that axis by a factor \( k \), where \( 0<k<1 \), while leaving the other coordinate(s) unchanged.
Below are visual representations of an expansion along the \(x\)-axis and a compression along the \(y\)-axis, both in \(\mathbb{R}^2\).

Shears
A shear transformation in \(\mathbb{R}^2\) is a linear transformation that shifts points in a fixed direction by an amount proportional to their perpendicular distance from a given axis. Shearing preserves the area of geometric shapes but distorts their angles, transforming rectangles into parallelograms.
Below are visual representations of a shear transformation in the \(x\)-direction with a positive shear factor, and a shear transformation in the \(y\)-direction with a negative shear factor.


This page titled 5.4: Special Linear Transformations in Two and Three Dimensions was last modified on Sat, 07 Jun 2025 23:18:58 GMT and is shared under a CC BY 4.0 license and was authored, remixed, and/or curated by Doli Bambhania, Fatemeh Yarahmadi, and Bill Wilson.
The book could not be loaded just now.