Opening the book…
We have now seen how to describe curves in the plane and in space, and how to determine their properties, such as arc length and curvature. All of this leads to the main goal of this section, which is the description of motion along plane curves and space curves. We now have all the tools we need; we put these ideas together and look at how to use them.
Our starting point is using vector-valued functions to represent the position of an object as a function of time. All of the following material can be applied either to curves in the plane or to space curves. For example, when we look at the orbit of the planets, the curves defining these orbits all lie in a plane because they are elliptical. However, a particle traveling along a helix moves on a curve in three dimensions.
Let \(\vecs r(t)\) be a twice-differentiable vector-valued function of the parameter \(t\) that represents the position of an object as a function of time.
The velocity vector \(\vecs v(t)\) of the object is given by
\[\text{Velocity}\,=\vecs v(t)=\vecs r^{\,\prime}(t) \nonumber \]
The acceleration vector \(\vecs a(t)\) is defined to be
\[\text{Acceleration}\,=\vecs a(t)=\vecs v^{\,\prime}(t)=\vecs r^{\,\prime\prime}(t) \nonumber\]
The speed is defined to be
\[\mathrm{Speed}\,=v(t)=‖\vecs v(t)‖=‖\vecs r^{\,\prime}(t)‖=\dfrac{ds}{dt} \nonumber \]
Since \(\vecs{r}(t)\) can be in either two or three dimensions, these vector-valued functions can have either two or three components. In two dimensions, we define \(\vecs{r}(t)=x(t) \hat{\mathbf i}+y(t) \hat{\mathbf j}\) and in three dimensions \(\vecs r(t)=x(t) \hat{\mathbf i}+y(t) \hat{\mathbf j}+z(t) \hat{\mathbf k}\). Then the velocity, acceleration, and speed can be written as shown in the following table.
| Quantity | Two Dimensions | Three Dimensions |
|---|---|---|
| Position | \(\vecs{r}(t)=x(t) \hat{\mathbf i}+y(t) \hat{\mathbf j}\) | \(\vecs{r}(t)=x(t) \hat{\mathbf i}+y(t) \hat{\mathbf j}+z(t) \hat{\mathbf k}\) |
| Velocity | \(\vecs{v}(t)=x^{\,\prime}(t) \hat{\mathbf i}+y^{\,\prime}(t) \hat{\mathbf j}\) | \(\vecs{v}(t)=x^{\,\prime}(t) \hat{\mathbf i}+y^{\,\prime}(t) \hat{\mathbf j}+z^{\,\prime}(t) \hat{\mathbf k}\) |
| Acceleration | \(\vecs{a}(t)=x^{\,\prime\prime}(t) \hat{\mathbf i}+y^{\,\prime\prime}(t) \hat{\mathbf j}\) | \(\vecs{a}(t)=x^{\,\prime\prime}(t) \hat{\mathbf i}+y^{\,\prime\prime}(t) \hat{\mathbf j}+z^{\,\prime\prime}(t) \hat{\mathbf k}\) |
| Speed | \(\|\vecs{v}(t)\|= \sqrt{(x^{\,\prime}(t))^2+(y^{\,\prime}(t))^2}\) | \(\|\vecs{v}(t)\|=\sqrt{(x^{\,\prime}(t))^2+(y^{\,\prime}(t))^2+(z^{\,\prime}(t))^2}\) |
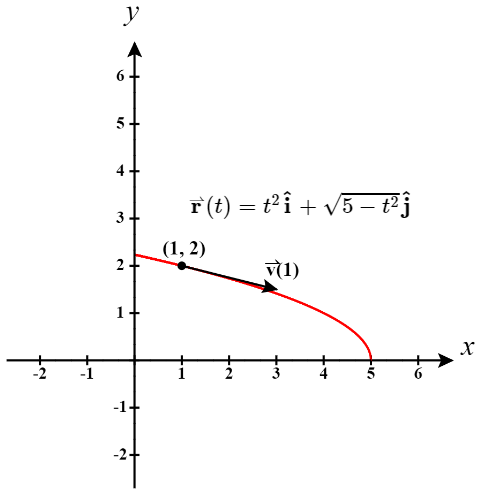
A particle moves in a parabolic path defined by the vector-valued function \(\vecs{r}(t)=t^2 \hat{\mathbf i}+ \sqrt{5−t^2} \hat{\mathbf j}\), where \(t\) measures time in seconds.
(a) Find the velocity, acceleration, and speed as functions of time.
(b) Sketch the curve along with the velocity vector at time \(t=1\).
Solution
(a) These are direct calculations:
\[ \begin{align*} \vecs{v}(t) &= \vecs{r}^{\,\prime}(t)=2t\hat{\mathbf i}−\dfrac{t}{\sqrt{5-t^2}}\hat{\mathbf j} \\[4pt] \vecs{a}(t) &=\vecs{v}^{\,\prime}(t)=2\hat{\mathbf i}−5(5−t^2)^{-\frac{3}{2}}\hat{\mathbf j} \\[4pt] ||\vecs{v}(t)|| &=||\vecs{r}^{\,\prime}(t)|| =\sqrt{(2t)^2+\left(-\dfrac{t}{\sqrt{5-t^2}}\right)^2}=\boxed{\sqrt{\dfrac{21t^2-4t^4}{5-t^2}}} \end{align*}\]
(b) The graph of \(\vecs{r}(t)=t^2 \hat{\mathbf i}+ \sqrt{5−t^2} \hat{\mathbf j}\) is a portion of a parabola.
When \(t=1\), \(\vecs r(1) = (1)^2 \mathbf{\hat i} + \sqrt{5-(1)^2} \mathbf{\hat j} \quad = \quad \mathbf{\hat i} + \sqrt{4} \mathbf{\hat j} \quad = \quad \mathbf{\hat i} + 2 \mathbf{\hat j}\)
Thus the particle would be located at the point \((1, 2)\) when \(\boxed{t =1}\)
The velocity vector at \(t=1\) is \(\vecs{v}(1) =\vecs{r}^{\,\prime}(1)=2(1)\hat{\mathbf i}−\dfrac{1}{\sqrt{5-1^2}} \hat{\mathbf j} = 2\hat{\mathbf i}−\dfrac{1}{2}\hat{\mathbf j} \)
and the acceleration vector at \(t=1\) is \( \vecs{a}(1)=\vecs{v}^{\,\prime}(1)=2\hat{\mathbf i}−5(5 - 1^2)^{-\frac{3}{2}}\hat{\mathbf j} = \boxed{2\hat{\mathbf i}−\dfrac{5}{8}\hat{\mathbf j} }\)
Notice that the velocity vector is tangent to the path, as is always the case.
Now let’s look at an application of vector functions. In particular, let’s consider the effect of gravity on the motion of an object as it travels through the air, and how it determines the resulting trajectory of that object. In the following, we ignore the effect of air resistance. This situation, with an object moving with an initial velocity but with no forces acting on it other than gravity, is known as projectile motion. It describes the motion of objects from golf balls to baseballs, and from arrows to cannonballs.
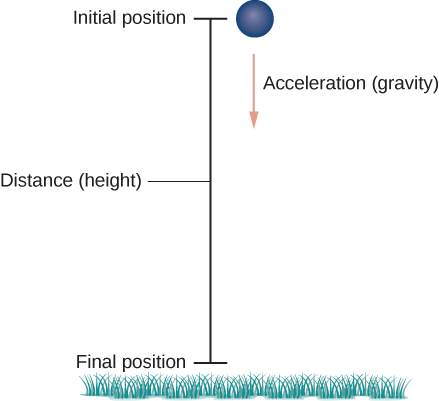
First we need to choose a coordinate system. If we are standing at the origin of this coordinate system, then we choose the positive \(y\)-axis to be up, the negative \(y\)-axis to be down, and the positive \(x\)-axis to be forward (i.e., away from the thrower of the object). The effect of gravity is in a downward direction, so Newton’s second law tells us that the force on the object resulting from gravity is equal to the mass of the object times the acceleration resulting from gravity, or \(\vecs F_g=m\vecs a\), where \(\vecs F_g\) represents the force from gravity and \(\vecs a = -g\,\hat{\mathbf j}\) represents the acceleration resulting from gravity at Earth’s surface. The value of \(g\) in the English system of measurement is approximately 32 ft/sec2 and it is approximately 9.8 m/sec2 in the metric system. This is the only force acting on the object. Since gravity acts in a downward direction, we can write the force resulting from gravity in the form \(\vecs F_g=−mg\,\hat{\mathbf j}\), as shown below:
Newton’s second law also tells us that \(F=m\vecs{a}\), where \(\vecs a\) represents the acceleration vector of the object. This force must be equal to the force of gravity at all times, so we therefore know that
\[ \vecs F =\vecs F_g \longleftrightarrow m\vecs{a} = -mg \,\hat{\mathbf j} \longleftrightarrow \vecs{a} = -g\,\hat{\mathbf j} \nonumber\]
Now we use the fact that the acceleration vector is the first derivative of the velocity vector. Therefore, we can rewrite the last equation in the form
\[\vecs v^{\,\prime}(t) = -g\,\hat{\mathbf j} \nonumber \]
By taking the antiderivative of each side of this equation we obtain
\[ \vecs v(t) = \int -g \,\hat{\mathbf j}\; dt = -gt\,\hat{\mathbf j} + \vecs C_1 \nonumber \]
for some constant vector \(\vecs C_1\). To determine the value of this vector, we can use the velocity of the object at a fixed time, say at time \(t=0\). We call this velocity the initial velocity: \(\vecs v(0)=\vecs v_0\). Therefore, \(\vecs v(0)=−g(0)\,\hat{\mathbf j}+\vecs C_1=\vecs v_0\) and \(\vecs C_1= \vecs v_0\). This gives the velocity vector as \(\vecs v(t)=−gt\,\hat{\mathbf j}+\vecs v_0\).
Next we use the fact that velocity \(\vecs{v}(t)\) is the derivative of position \(\vecs{s}(t)\). This gives the equation
\[\vecs s^{\,\prime}(t)=-gt\,\hat{\mathbf j}+\vecs{v}_0. \nonumber \]
Taking the antiderivative of both sides of this equation leads to
\[ \vecs s(t) = \int -gt\,\hat{\mathbf j} + \vecs{v}_0 \;dt = -\dfrac{1}{2}gt^2 \,\hat{\mathbf j} + \vecs{v}_0 t + \vecs{C}_2 \nonumber\]
with another unknown constant vector \(\vecs{C}_2\). To determine the value of \(\vecs{C}_2\), we can use the position of the object at a given time, say at time \(t=0\). We call this position the initial position: \(\vecs{s}(0)=\vecs{s}_0\). Therefore, \(\vecs{s}(0)=−\dfrac{1}{2}g(0)^2\,\hat{\mathbf j}+\vecs{v}_0(0)+\vecs{C}_2=\vecs{s}_0\). Clearly \(\vecs{C}_2=\vecs{s}_0\), which gives the position of the object at any time as
\[ \vecs{s}(t)=−\dfrac{1}{2}gt^2 \,\hat{\mathbf j}+\vecs{v}_0 t+\vecs{s}_0 \nonumber \]
Let’s take a closer look at the initial velocity and initial position. In particular, suppose the object is thrown upward from the origin at an angle \(\theta\) to the horizontal, with initial speed \(\vecs{v}_0\). How can we modify the previous result to reflect this scenario? First, we can assume it is thrown from the origin. If not, then we can move the origin to the point from where it is thrown. Therefore, \(\vecs{s}_0=\vecs{0}\), as shown below.
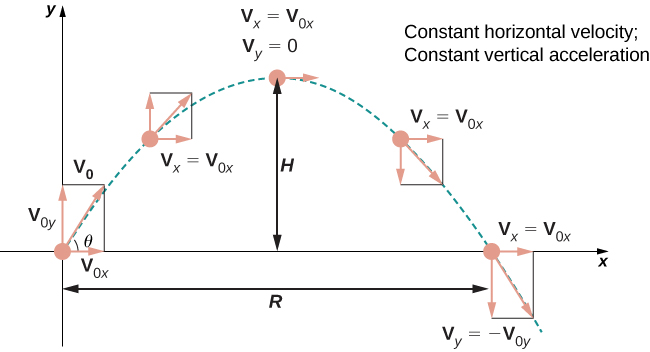
The horizontal motion is at constant velocity and the vertical motion is at constant acceleration.
We can rewrite the initial velocity vector in the form \(\vecs{v}_0= v_0 \cos (\theta) \,\hat{\mathbf i} + v_0 \sin (\theta) \,\hat{\mathbf j}\). Then the equation for the position function \(\vecs{s}(t)\) becomes
\[\vecs{s}(t) =-\dfrac{1}{2} gt^2\,\hat{\mathbf j} + v_0 t \cos(\theta) \,\hat{\mathbf i} + v_0 t \sin(\theta) \,\hat{\mathbf j}= v_0 t \cos(\theta) \,\hat{\mathbf i} + \left(v_0 t \sin(\theta) - \dfrac{1}{2} gt^2\right)\,\hat{\mathbf j}\nonumber \]
The coefficient of \(\hat{\mathbf i}\) represents the horizontal component of \(\vecs{s}(t)\) and is the horizontal distance of the object from the origin at time \(t\). The maximum value of the horizontal distance (measured at the same initial and final altitude) is called the range \(R\). The coefficient of \(\hat{\mathbf j}\) represents the vertical component of \(\vecs{s}(t)\) and is the altitude of the object at time \(t\). The maximum value of the vertical distance is the height \(H\).
During an Independence Day celebration, a cannonball is fired from a cannon on a cliff toward the water. The cannon is aimed at an angle of \(\sin^{-1}\left(\dfrac{1}{4}\right)\) above horizontal and the initial speed of the cannonball is 600 ft/sec. The cliff is 100 ft above the water.
(a) Find the maximum height of the cannonball.
(b) How long will it take for the cannonball to splash into the sea?
(c) How far out to sea will the cannonball hit the water?
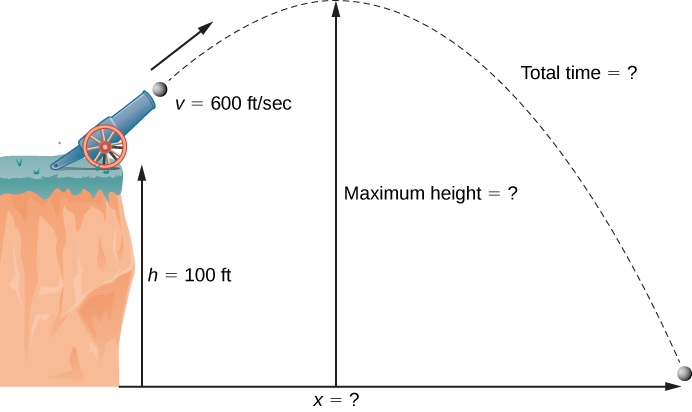
We use the equation \(\vecs{s}(t) = v_0 t \cos(\theta) \,\hat{\mathbf i} + \left(v_0 t \sin(\theta) - \dfrac{1}{2}gt^2 \right)\,\hat{\mathbf j} \) with \(\theta=\sin^{-1}\left(\dfrac{1}{4}\right) \), \(g=32 \,\dfrac{\text{ft}}{\text{sec}^2}\), and \(v_0=600 \,\dfrac{\text{ft}}{\text{sec}}\).
This position equation becomes
\[\begin{align*} \vecs{s}(t) &= 600 t ( \cos \left( \sin^{-1}\left(\dfrac{1}{4}\right)\right)\,\hat{\mathbf i} + \left(600t \sin\left( \sin^{-1}\left(\dfrac{1}{4}\right)\right) - \dfrac{1}{2}(32)t^2 \right)\,\hat{\mathbf j} \\[4pt] &= 150t\sqrt{15} \,\hat{\mathbf i} + \left( 150t - 16t^2 \right)\,\hat{\mathbf j} \end{align*}\]
(a) The cannonball reaches its maximum height when the vertical component of its velocity is zero, because the cannonball is neither rising nor falling at that point. The velocity vector is
\[ \vecs{v}(t) =\vecs s^{\,\prime}(t) = 150 \sqrt{15} \,\hat{\mathbf i} + (150-32t)\,\hat{\mathbf j} \nonumber \]
Therefore, the vertical component of velocity is given by the expression \(150−32t\). Setting this expression equal to zero and solving for \(t\) gives \(t=\dfrac{75}{16}\) sec. The height of the cannonball at this time is given by the vertical component of the position vector:
\[ H=150\left(\dfrac{75}{16}\right)−16\left(\dfrac{75}{16}\right)^2= \dfrac{5625}{16}= 351.5625\nonumber \]
Therefore, the maximum height of the cannonball is 351.5625 ft above the cannon, or 451.5625 ft above sea level.
(b) When the cannonball lands in the water, it is 100 ft below the cannon. Therefore, the vertical component of the position vector is equal to \(−100.\) Setting the vertical component of \(\vecs s(t)\) equal to \(−100\) and solving, we obtain
\[\begin{align*} 150t-16t^2 = -100 \\ 16t^2-150t-100 =0 \\ 2(t-10)(8t+5) =0 \\ t=10, -\dfrac{5}{8} \end{align*}\]
The positive value of \(t\) that solves this equation is 10. Therefore, the cannonball hits the water after 10 sec.
(c) To find the distance out to sea, we simply substitute the answer from part (b) into the horizontal component of \(\vecs{s}(t)\):
\[D=150(10)\sqrt{15}=1500\sqrt{15}\approx 5809.475\nonumber \]
Therefore, the ball hits the water about 5809.475 ft away from the base of the cliff.
Note that 5809.475 feet is not the true range of the cannon since the cannonball lands in the ocean at a location below the cannon. The range of the cannon would be determined by finding how far out the cannonball is when its height is 100 ft above the water (the same as the altitude of the cannon).
One final question remains: In general, what is the maximum distance a projectile can travel, given its initial speed? To determine this distance, we assume the projectile is fired from ground level and we wish it to return to ground level. In other words, we want to determine an equation for the range. In this case, the equation of projectile motion is
\[\vecs{s}=v_0 t \cos(\theta )\,\hat{\mathbf i} + \left(v_0t\sin(\theta) - \dfrac{1}{2}gt^2 \right)\,\hat{\mathbf j} \nonumber \]
Setting the second component equal to zero and solving for \(t\) yields
\[\begin{align*} v_0 t \sin(\theta) - \dfrac{1}{2}gt^2 =0\\ t\left(v_0 \sin(\theta) - \dfrac{1}{2}gt\right) =0 \end{align*}\]
Therefore, either \(t=0\) or \(t=\dfrac{2v_0\sin\theta}{g}\). We are interested in the second value of \(t\), so we substitute this into \(\vecs{s}(t)\), which gives
\[ \vecs{s}\left(\dfrac{2v_0\sin(\theta)}{g} \right) = v_0 \left(\dfrac{2v_0\sin(\theta)}{g} \right) \cos\theta \,\hat{\mathbf i} + \left( v_0\left(\dfrac{2v_0\sin(\theta)}{g} \right)\sin(\theta) - \dfrac{1}{2}g\left(\dfrac{2v_0\sin(\theta)}{g} \right)^2 \right)\,\hat{\mathbf j} = \dfrac{v_0^2 \sin(2\theta)}{g}\,\hat{\mathbf i} \nonumber \]
Thus, the expression for the range of a projectile fired at an angle \(\theta\) is
\[R=\dfrac{v_0^2 \sin(2\theta)}{g}\,\hat{\mathbf i} \nonumber \]
The only variable in this expression is \( \theta\). To maximize the distance traveled, take the derivative of the coefficient of \( \hat{\mathbf i} \) with respect to \(\theta\) and set it equal to zero:
\[ \dfrac{d}{d\theta} \left( \dfrac{v_0^2 \sin(2\theta)}{g} \right) =0\longleftrightarrow \dfrac{2v_0^2\cos(2\theta)}{g} =0\longleftrightarrow \theta=45^\circ \nonumber\]
This value of \(\theta\) is the smallest positive value that makes the derivative equal to zero. Therefore, in the absence of air resistance, the best angle to fire a projectile (to maximize the range) is at a 45° angle. The distance it travels is given by
\[\vecs{s}\left(\dfrac{2v_0 \sin( 45^\circ)}{g} \right)= \dfrac{v_0^2 \sin (90^\circ)}{g} \,\hat{\mathbf i} = \dfrac{v_0^2}{g}\,\hat{\mathbf i} \nonumber \]
Therefore, the range for an angle of 45° is \(\dfrac{v_0^2}{g}\) units.
During the early 1600s, Johannes Kepler was able to use the amazingly accurate data from his mentor Tycho Brahe to formulate his three laws of planetary motion, now known as Kepler’s laws of planetary motion. These laws also apply to other objects in the solar system in orbit around the Sun, such as comets (e.g., Halley’s comet) and asteroids. Variations of these laws apply to satellites in orbit around Earth.
- The path of any planet about the Sun is elliptical in shape, with the center of the Sun located at one focus of the ellipse (the law of ellipses).
- A line drawn from the center of the Sun to the center of a planet sweeps out equal areas in equal time intervals (the law of equal areas) (Figure \(\PageIndex{5}\)).
- The ratio of the squares of the periods of any two planets is equal to the ratio of the cubes of the lengths of their semimajor orbital axes (the Law of Harmonies).
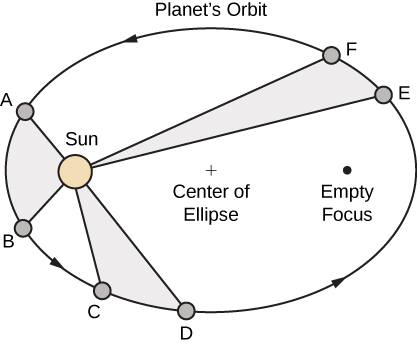
Kepler’s third law is especially useful when using appropriate units. In particular, 1 astronomical unit is defined to be the average distance from Earth to the Sun, and is now recognized to be 149,597,870,700 m or, approximately 93,000,000 mi. We therefore write 1 A.U. = 93,000,000 mi. Since the time it takes for Earth to orbit the Sun is 1 year, we use Earth years for units of time. Then, substituting 1 year for the period of Earth and 1 A.U. for the average distance to the Sun, Kepler’s third law can be written as
\[ T_p^2=D_p^3 \nonumber \]
for any planet in the solar system, where \(T_P\) is the period of that planet measured in Earth years and \(D_P\) is the average distance from that planet to the Sun measured in astronomical units. Therefore, if we know the average distance from a planet to the Sun (in astronomical units), we can then calculate the length of its year (in Earth years), and vice versa.
Kepler’s laws were formulated based on observations from Brahe; however, they were not proved formally until Sir Isaac Newton was able to apply calculus. Furthermore, Newton was able to generalize Kepler’s third law to other orbital systems, such as a moon orbiting around a planet. Kepler’s original third law only applies to objects orbiting the Sun.
Let’s now prove Kepler’s first law using the calculus of vector-valued functions. First we need a coordinate system. Let’s place the Sun at the origin of the coordinate system and let the vector-valued function \(\vecs{r}(t)\) represent the location of a planet as a function of time. Newton proved Kepler’s law using his second law of motion and his law of universal gravitation. Newton’s second law of motion can be written as \(\vecs{F}=m\vecs{a}\), where \(\vecs{F}\) represents the net force acting on the planet. His law of universal gravitation can be written in the form \(\vecs{F}=−\dfrac{GmM}{||\vecs{r}||^2}\cdot \dfrac{\vecs{r}}{||\vecs{r} ||}\), which indicates that the force resulting from the gravitational attraction of the Sun points back toward the Sun, and has magnitude \(\dfrac{GmM}{||\vecs{r}||^2} \).
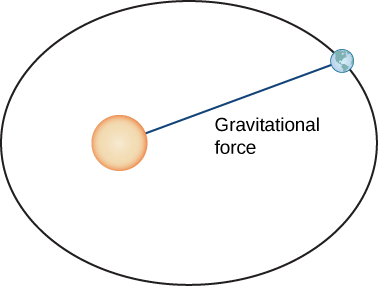
Setting these two forces equal to each other, and using the fact that \(\vecs a(t)=\vecs v^{\,\prime}(t)\), we obtain
\[ m\vecs v^{\,\prime}(t)=−\frac{GmM}{‖\vecs r‖^2}⋅\frac{\vecs r}{‖\vecs r‖} \nonumber \]
which can be rewritten as
\[ \dfrac{d\vecs v}{dt}=−\dfrac{GM}{||\vecs r||^3}\vecs{r} \nonumber \]
This equation shows that the vectors \(\dfrac{d\vecs{v}}{dt}\) and \(\vecs r\) are parallel to each other, so \(\dfrac{d\vecs{v}}{dt} \times \vecs {r}=\vecs 0\). Next, let’s differentiate \(\vecs{r} \times \vecs{v}\) with respect to time:
\[\dfrac{d}{dt}(\vecs{r}\times \vecs{v})=\dfrac{d\vecs{r}}{dt}\times \vecs v+\vecs{r} \times \dfrac{d\vecs{v}}{dt}=\vecs{v}\times \vecs{v}+\vecs{0}=\vecs{0} \nonumber \]
This proves that \(\vecs{r}\times\vecs{v}\) is a constant vector, which we call \(\vecs C\). Since \(\vecs r\) and \(\vecs v\) are both perpendicular to \(\vecs C\) for all values of \(t\), they must lie in a plane perpendicular to \(\vecs C\). Therefore, the motion of the planet lies in a plane.
Next we calculate the expression \(\dfrac{d\vecs{v}}{dt}\times \vecs C\):
\[\dfrac{d\vecs{v}}{dt} \times \vecs{C}=−\dfrac{GM}{||\vecs{r}||^3}\vecs{r}\times (\vecs{r}\times\vecs{v})=−\dfrac{GM}{||\vecs r||^3}[(\vecs{r} \cdot \vecs{v})\vecs{r} - (\vecs{r} \cdot \vecs{r})\vecs{v}] \nonumber \]
The last equality above is from the triple cross product formula. We need an expression for \(\vecs{r}\cdot \vecs{v}\). To calculate this, we differentiate \(\vecs{r}\cdot \vecs{r}\) with respect to time:
\[ \dfrac{d}{dt}(\vecs{r}\cdot \vecs{r})=\dfrac{d\vecs{r}}{dt}\cdot \vecs{r}+\vecs{r}\cdot \dfrac{d\vecs{r}}{dt}=2\vecs{r}\cdot \dfrac{d\vecs{r}}{dt}=2\vecs{r}\cdot \vecs{v} \nonumber \]
Since \(\vecs{r}\cdot\vecs{r}=||\vecs r||^2\), we also have
\[\dfrac{d}{dt}(\vecs{r}\cdot \vecs{r})=\dfrac{d}{dt}||\vecs{r}||^2=2||\vecs{r}|| \dfrac{d}{dt}||\vecs{r}|| \nonumber \]
Combining these two equations, we get
\[\begin{align*} 2\vecs{r}\cdot \vecs{v} =2||\vecs{r}||\dfrac{d}{dt}||\vecs{r}|| \\ \vecs{r} \cdot \vecs{v} =||\vecs{r}‖\dfrac{d}{dt}||\vecs{r}|| \end{align*} \nonumber \]
Substituting this into the equation for \(\dfrac{d\vecs{v}}{dt}\times \vecs C\) gives us:
\[ \dfrac{d\vecs{v}}{dt} \times \vecs{C} = - \dfrac{GM}{||\vecs{r}||^3} [(\vecs{r}\cdot \vecs{v})\vecs{r} - (\vecs{r}\cdot \vecs{r})\vecs{v}] \nonumber \]
\[ = -\dfrac{GM}{||\vecs{r}||^3}\left[ ||\vecs{r}|| \left(\dfrac{d}{dt} ||\vecs{r}||\right)\vecs{r} - ||\vecs{r}||^2\vecs{v} \right] \nonumber \]
\[ = -GM\left[ \dfrac{1}{||\vecs{r}||^2}\left( \dfrac{d}{dt} ||\vecs{r}|| \right)\vecs{r} - \dfrac{1}{||\vecs{r}||}\vecs{v} \right] \nonumber \]
\[ = GM\left[ \dfrac{\vecs{v}}{||\vecs{r}||} -\dfrac{\vecs{r}}{||\vecs{r}||^2}\left( \dfrac{d}{dt} ||\vecs{r}|| \right) \right] \nonumber \]
However,
\[ \begin{align*} \dfrac{d}{dt} \dfrac{\vecs{r}}{||\vecs{r}||} = \dfrac{ \frac{d}{dt}(\vecs{r})||\vecs{r}||- \vecs{r}\frac{d}{dt}||\vecs{r}|| }{||\vecs{r}||^2} \\ = \dfrac{ \frac{d\vecs{r}}{dt} }{||\vecs{r}||} - \dfrac{\vecs{r}}{||\vecs{r}||^2}\dfrac{d}{dt}||\vecs{r} || \\ = \dfrac{\vecs{v}}{||\vecs{r}||} - \dfrac{\vecs{r}}{||\vecs{r}||^2} \dfrac{d}{dt}||\vecs{r}|| \end{align*}\]
Which makes the \(\dfrac{d\vecs{v}}{dt}\times \vecs C\) equation simplify to
\[\dfrac{d \vecs{v}}{dt}\times \vecs{C}=GM\left( \dfrac{d}{dt}\dfrac{ \vecs{r}}{ || \vecs{r} ||} \right)\nonumber \]
Since \(\vecs{C}\) is a constant vector, we can integrate both sides and obtain
\[ \vecs{v}\times\vecs{C} = GM \dfrac{ \vecs{r} }{|| \vecs{r} ||} + \vecs{D} \nonumber \]
where \(\vecs D\) is a constant vector. Our goal is to solve for \(|| \vecs{r} ||\). Let’s start by calculating \( \vecs{r} \cdot \left( \vecs{v}\times \vecs{C} \right)\):
\[\vecs{r} \cdot \left( \vecs{v}\times \vecs{C} \right) =GM\dfrac{||\vecs{r}||^2}{||\vecs{r}||}+ \vecs{r}\cdot\vecs{D} =GM||\vecs{r}||+\vecs{r}\cdot \vecs{D} \nonumber \]
However, \( \vecs{r} \cdot ( \vecs{v}\times \vecs{C})= ( \vecs{r} \times \vecs{v})\cdot \vecs{C} \), so
\[ ( \vecs{r} \times \vecs{v})\cdot \vecs{C} =GM||\vecs{r}|| + \vecs{r}\cdot \vecs{D}\nonumber \]
Since \(\vecs{r}\times \vecs{v}=\vecs{C}\), we have
\[ ||\vecs{C}||^2 =GM||\vecs{r}|| +\vecs{r}\cdot \vecs{D}\nonumber \]
Note that \( \vecs{r} \cdot \vecs{D}=||\vecs{r}|| ||\vecs{D}||\cos (\theta) \), where \(\theta\) is the angle between \(\vecs{r}\) and \(\vecs{D}\). Therefore,
\[ ||\vecs{C}||^2=GM||\vecs{r}||+||\vecs{r}|| ||\vecs{D}|| \cos(\theta) \nonumber \]
Solving for \(||\vecs{r}||\),
\[ ||\vecs{r}|| = \dfrac{||\vecs{C}||^2 }{GM+||\vecs{D}||\cos(\theta)} = \dfrac{||\vecs{C}||^2}{GM}\left( \dfrac{1}{1+e\cos\theta} \right) \nonumber \]
where \(e=\dfrac{||\vecs{D}||}{GM}\). This is the polar equation of a conic with a focus at the origin, which we set up to be the Sun. It is a hyperbola if \(e>1\), a parabola if \(e=1\), or an ellipse if \(e<1\). Since planets have closed orbits, the only possibility is an ellipse. However, at this point it should be mentioned that hyperbolic comets do exist. These are objects that are merely passing through the solar system at speeds too great to be trapped into orbit around the Sun. As they pass close enough to the Sun, the gravitational field of the Sun deflects the trajectory enough so the path becomes hyperbolic.
This page titled 1.7: Motion in Space was last modified on Wed, 15 Apr 2026 19:07:21 GMT and is shared under a CC BY-NC 4.0 license and was authored, remixed, and/or curated by Kenn Huber via source content that was edited to the style and standards of the LibreTexts platform.
The book could not be loaded just now.